WP1 phase implemented by Łukasiewicz IMPIB.
The objective of WP1 is the selection and characterization of bio-based binder systems for two-component protective coatings intended for concrete and vacuum environments. This includes polyols, bio-based isocyanates, and NISO systems for the synthesis of polyurethanes, polyureas, polyaspartics, and bio-epoxies, with a focus on reducing fossil-based raw materials and eliminating toxic curing agents.
Completion of WP3
WP3 phase implemented by SPE Labs.
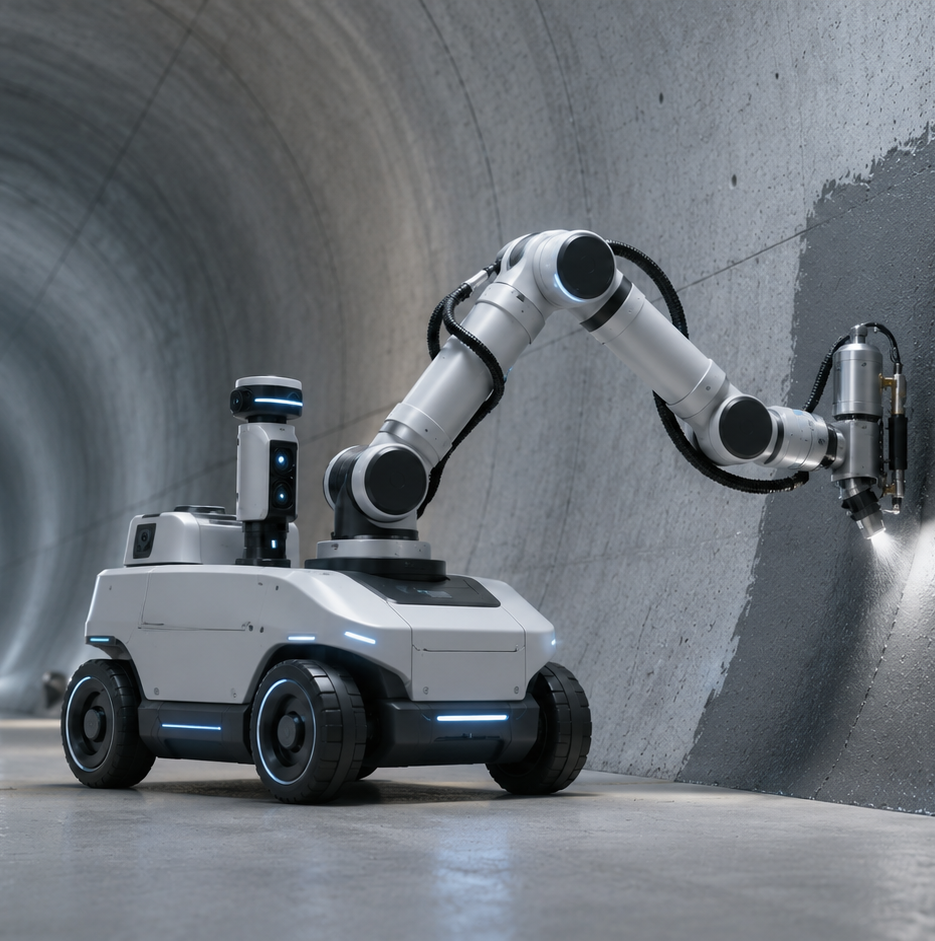
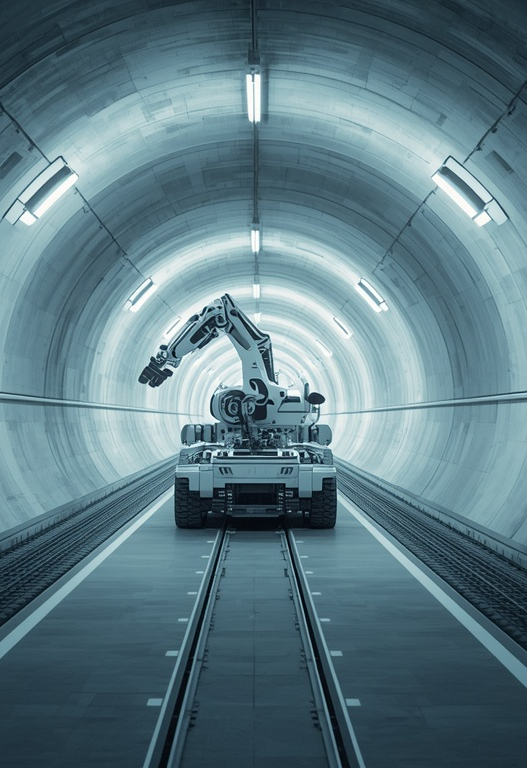
WP3 encompasses research and development activities focused on the design and development of key subsystems of the AMMMV demonstrator, carried out in parallel across the following areas: inspection system, data processing, repair coating application system, and functional chassis.
The phase includes requirements analysis, component selection, and the execution of studies and testing aimed at assessing the feasibility and integration of individual solutions within the future demonstrator.
Completion of WP2
WP2 involves the development and preliminary validation of prototype, bio-based two-component coating systems (2K) intended for two main application areas: conventional construction (atmospheric conditions) and Hyperloop infrastructure operating under reduced pressure and vacuum conditions.
Within this work, compatible primer and topcoat systems will be developed based on binders from WP1, as well as environmentally friendly pigments and fillers. The coatings will be optimized for application on two types of concrete substrates, ensuring high adhesion, mechanical and chemical resistance, and reduced gas permeability (O₂, CO₂).
Completion of WP4
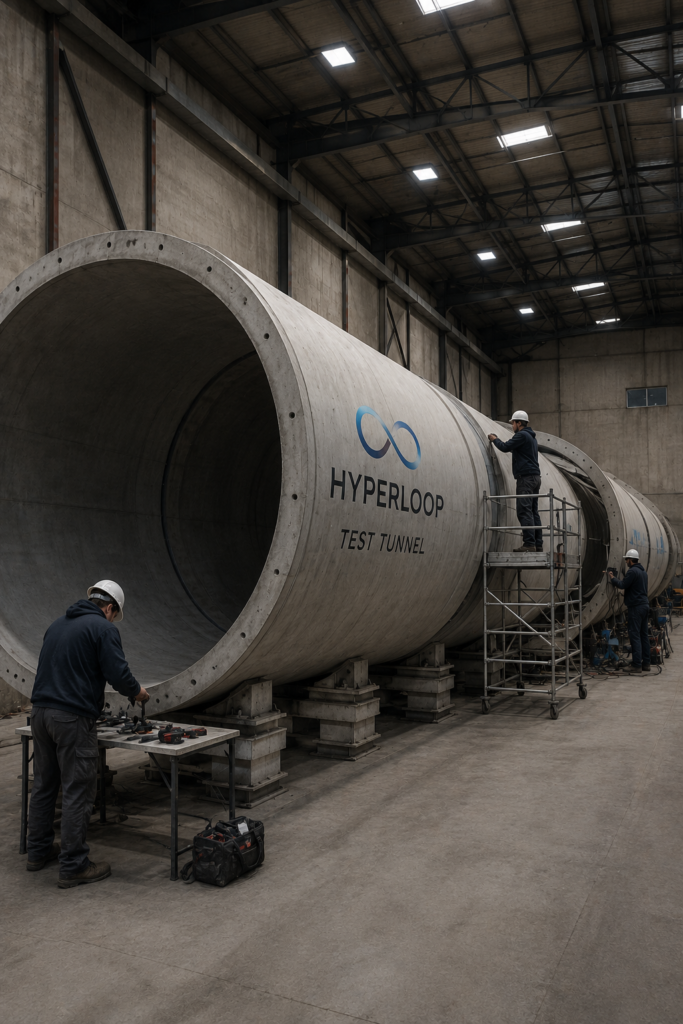
The task involves the preparation and use of advanced environmental chambers for the validation of bio-based coating systems under conditions representative of transport infrastructure operation, including Hyperloop.
The work includes the simulation of temperature variations, humidity, and vacuum conditions, as well as continuous monitoring of the behavior of coated concrete panels. Tests of the mechanical durability and environmental resistance of coatings developed in WP2 will be conducted under extreme conditions.
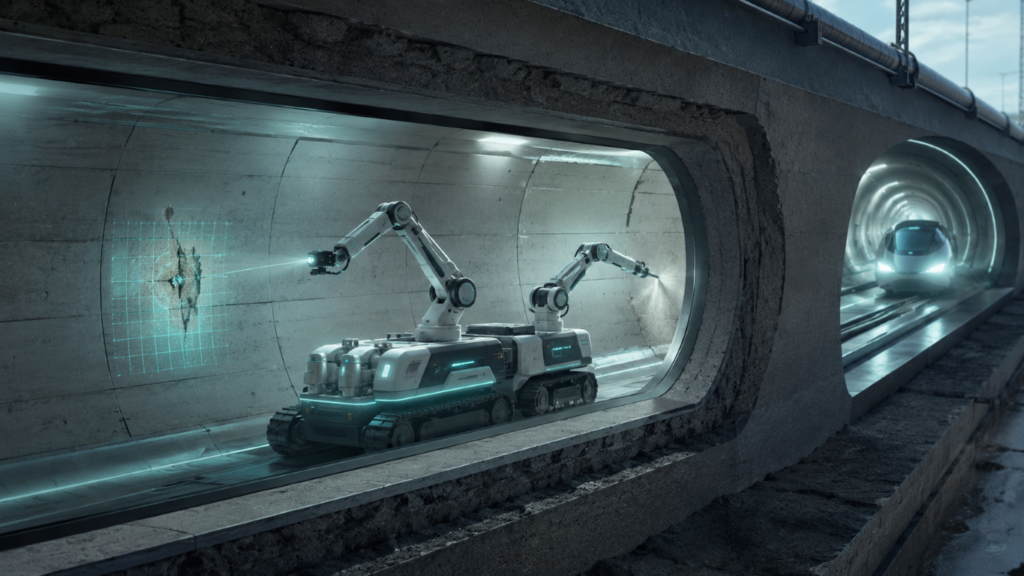
Additionally, samples with controlled defects will be used to validate damage detection systems and robotic repair solutions developed in WP3, including the evaluation of computer vision algorithms and coating application processes. WP4 also includes the integration and cross-validation of WP2 and WP3 results in order to enable iterative improvement of the overall system.
Completion of WP5
WP5 focuses on the integration of all previously developed subsystems into the first functional prototype of an Autonomous Monitoring and Maintenance Mobile Vehicle (AMMMV), and on its evaluation under conditions representative of Hyperloop operation.
The scope of work includes the integration of coating systems, the robotic application unit, and defect detection algorithms into a single unified system, along with mechanical, hardware, and software integration based on industrial communication interfaces and a central real-time controller. A dedicated user interface will also be developed for system monitoring and configuration.
Validation will be carried out in an environment simulating Hyperloop conditions (temperature, humidity, lighting, and reduced pressure), enabling the identification of technological limitations, assessment of the system’s maturity level, and definition of directions for further optimization and development.
Completion of WP6
WP6 supervised by the EuroTube Foundation with the participation of Łukasiewicz – IMPIB and SPE Labs, covers the final integration, optimization, and demonstration of the complete autonomous infrastructure maintenance system. The objective is to develop a second, improved iteration and to confirm the technology readiness through a proof-of-concept demonstration in the EuroTube test infrastructure.
The work includes the integration of all project subsystems, including coating formulations, robotic application, defect detection algorithms, and the autonomous maintenance system. Ł-IMPiB is responsible for developing coatings for both indoor and outdoor applications, compatible with robotic systems and resistant to environmental conditions, including vacuum.
A key element is the demonstration in the EuroTube test tunnel, involving automated coating application, defect detection, and autonomous repair, enabling the evaluation of system effectiveness, reliability, and operational efficiency.